In roll-to-roll (R2R), winding and unwinding, film, paper, and metal foil transport, printing and coating, and wire handling equipment, common signs of unstable tension include poor response in low-tension ranges, sudden control difficulties within a certain operating range, tension drift after extended operation, and inconsistent results between shifts using the same recipe.
In many cases, these issues are not caused by a faulty sensor or improperly tuned controller parameters. The actual cause may be the actuator—the magnetic powder brake—and whether its torque output is sufficiently linear, stable, and repeatable within the required operating range.
From an engineering application perspective, this article explains the core concepts of torque linearity and torque stability, how to interpret characteristic curves, differences between operating scenarios, key selection criteria, and practical on-site calibration methods. The goal is to convert a subjective impression that the system is “difficult to control” into conditions that can be measured, verified, and improved.
1) Starting with the problem: Why does torque linearity directly affect tension control?
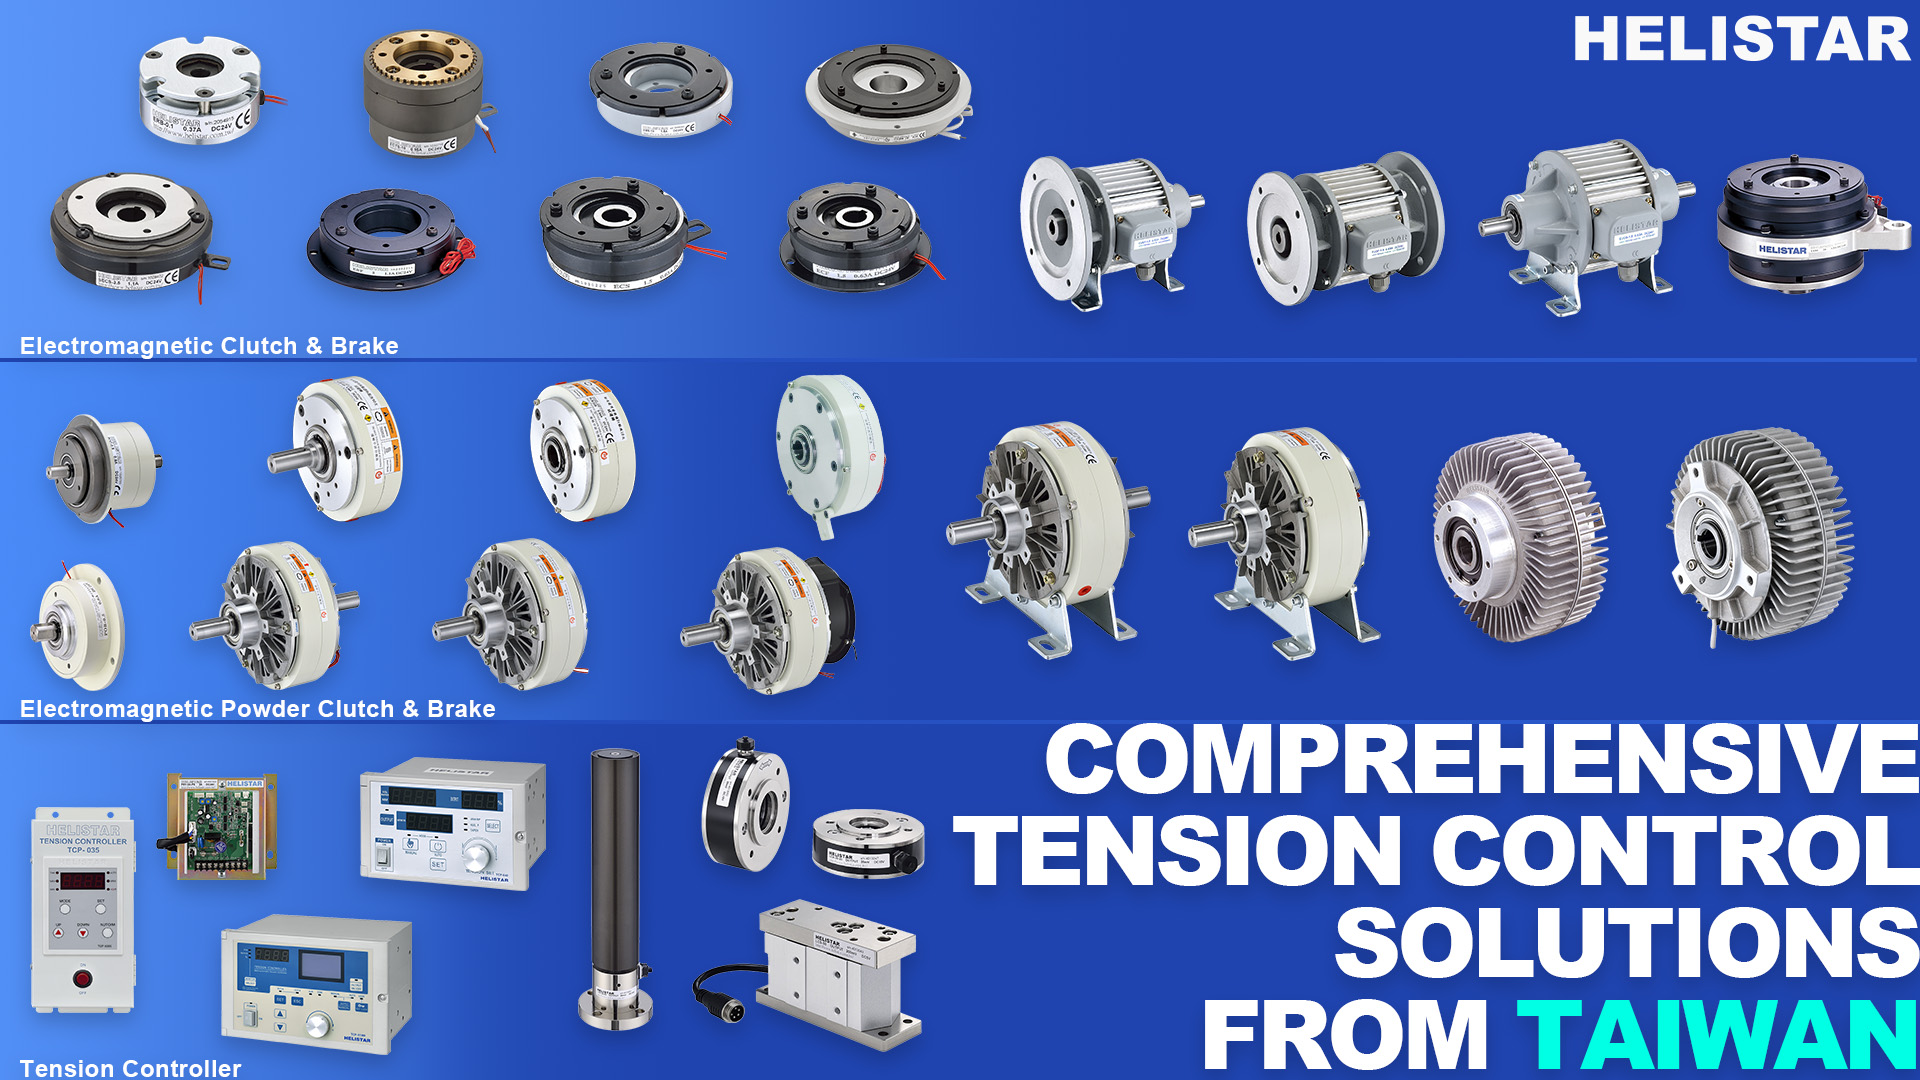
A magnetic powder brake uses coil current to generate a magnetic field. The magnetic powder forms chains within the working gap, creating shear resistance and producing braking torque. Ideally, torque changes approximately in proportion to current—this is what engineers refer to as torque linearity.
In tension control, the relationship between tension and torque can be described using the following practical equation—the only formula used in this article:
Tension F ≈ Torque T / Effective radius R
In practical terms, with the same torque, a smaller roll diameter produces higher tension, while a larger roll diameter produces lower tension.
Therefore, whenever torque is nonlinear relative to current—or the torque produced by the same current drifts—the controller may encounter the following typical difficulties:
- The same control parameters perform very differently across torque ranges: One range may respond too slowly, while another may be overly sensitive because the effective gain keeps changing.
- Low tension becomes especially difficult to control: The low-current region is more likely to fall within a nonlinear range or dead zone.
- Drift occurs after the system reaches operating temperature: Actual torque may no longer follow the curve measured during a cold start.
- Tension spikes are more likely during roll changes, acceleration, or deceleration: Changes in radius R combine with torque nonlinearity, making tension more difficult to stabilize.
2) Why are magnetic powder brakes suitable for tension applications? The key is the controllable range—not maximum torque
Magnetic powder brakes are commonly used in tension-control systems not only because their output can be adjusted continuously, but also because, within an appropriate operating range, they can provide:
- Smooth torque output: Torque fluctuation is generally lower than with mechanical friction brakes.
- A usable linear region: This supports closed-loop control and controller tuning.
- Repeatability that can be managed through engineering methods: Operating-point definition, thermal management, calibration tables, and other measures can keep performance within a controllable range.
However, the prerequisite for effective use is that the normal operating point must remain within the brake’s linear region, without approaching saturation or experiencing excessive drift caused by prolonged high-temperature operation.
This is why selecting a magnetic powder brake based only on rated torque can easily lead to problems.
3) Application comparison: Which applications depend most on torque linearity, and which depend most on torque stability?
A. Unwinder: Low tension and wide roll-radius variation
- Typical risk: The low-current region may show poor initial response, while small fluctuations can cause tension drift.
- Recommended approach:
- Position the normal torque requirement in the lower-middle portion of the usable linear region rather than close to zero torque.
- Use tension feedback from a load cell or dancer so that the tension controller can compensate for nonlinearity and drift.
B. Winder: High torque demand, frequent dynamic changes, and significant temperature rise
- Typical risk: Near the saturation region, increasing current produces little additional torque. Dynamic tension becomes difficult to suppress, while the torque coefficient may drift during extended operation.
- Recommended approach:
- Keep the normal operating torque near the middle of the linear region, preserving sufficient margin for acceleration, deceleration, and process disturbances.
- Prioritize verification of heat-dissipation conditions during continuous operation and torque stability at operating temperature.
C. Wire, metal foil, and composite materials: Narrow tension window and high quality costs
- Typical risk: Hysteresis, repeatability, and thermal drift can directly affect elongation, thickness uniformity, and surface defects.
- Recommended approach:
- Use torque stability and repeatability as selection and acceptance criteria.
- When necessary, establish a torque-current calibration table for lookup-table compensation and perform periodic reverification.
4) Key selection and specification criteria: Turning “linearity” into practical selection requirements
4.1 First determine your operating torque range
In practice, begin by calculating the required torque range from the process tension, including at least the maximum and minimum roll diameters:
- Target tension range, including acceleration, deceleration, and process disturbances
- Maximum and minimum roll diameters or effective radius R
- Line speed, slip conditions, and continuous operating time
Next, plot the normal torque operating points against the supplier’s torque-current curve.
Determine whether the operating points fall within the initial nonlinear region, the usable linear region, or near the saturation region.
4.2 Review the curve—not only the rated torque
When selecting a magnetic powder brake, such as a PLB or PFB series model, ask the supplier to confirm or provide at least the following information in addition to rated torque:
- Torque-current curve, preferably with stated test conditions such as speed, temperature, and test duration
- Recommended operating range within the linear region, such as the portion of rated torque considered optimal for control
- Hysteresis and repeatability, including whether increasing-current and decreasing-current curves overlap and whether repeated cycles at the same current produce consistent results
- Performance at operating temperature, including whether the torque coefficient changes significantly after the temperature reaches steady state
4.3 Match the drive method and controller: Prioritize current control and sufficient resolution
Whether torque appears linear depends substantially on how the coil is driven:
- Prioritize current-mode control: When voltage is used to drive the coil, temperature-related increases in coil resistance can change the current. Current drift leads directly to torque drift.
- Ensure sufficient output resolution: If each controller step produces a large current change, the low-tension range may alternate between being too loose and too tight.
- Apply linearization when necessary: Piecewise-linear compensation or lookup-table compensation within the tension controller can be used to correct the nonlinear range.
5) Common misconceptions and practical considerations
6) Measurement and calibration recommendations: Measuring and compensating for torque linearity and stability
If nonlinearity or thermal drift is suspected, establish a repeatable torque-current relationship under the actual operating conditions of the equipment:
- Keep test conditions consistent: Use a fixed speed or slip condition and fixed cooling conditions, and record both housing temperature and ambient temperature.
- Test both increasing and decreasing current: This reveals hysteresis by showing whether the same current produces the same torque in both directions.
- Sample densely around normal operating points: It is unnecessary to measure the entire range at very small intervals, but the most frequently used current range should be measured in detail.
- Establish lookup-table compensation when necessary: Convert the relationship between target torque and corresponding current into a lookup table or piecewise-linear curve for the tension controller or PLC output.
This method does not require the hardware to be perfectly linear by nature. Instead, it uses engineering controls to make system behavior predictable and repeatable within the required operating range.